Moving objects as a team
- Objects must be placed on opposite shelf to force handoffs
- Planner recognizes blue objects must be placed before orange
- Paper scales to 16 robots and 60 objects
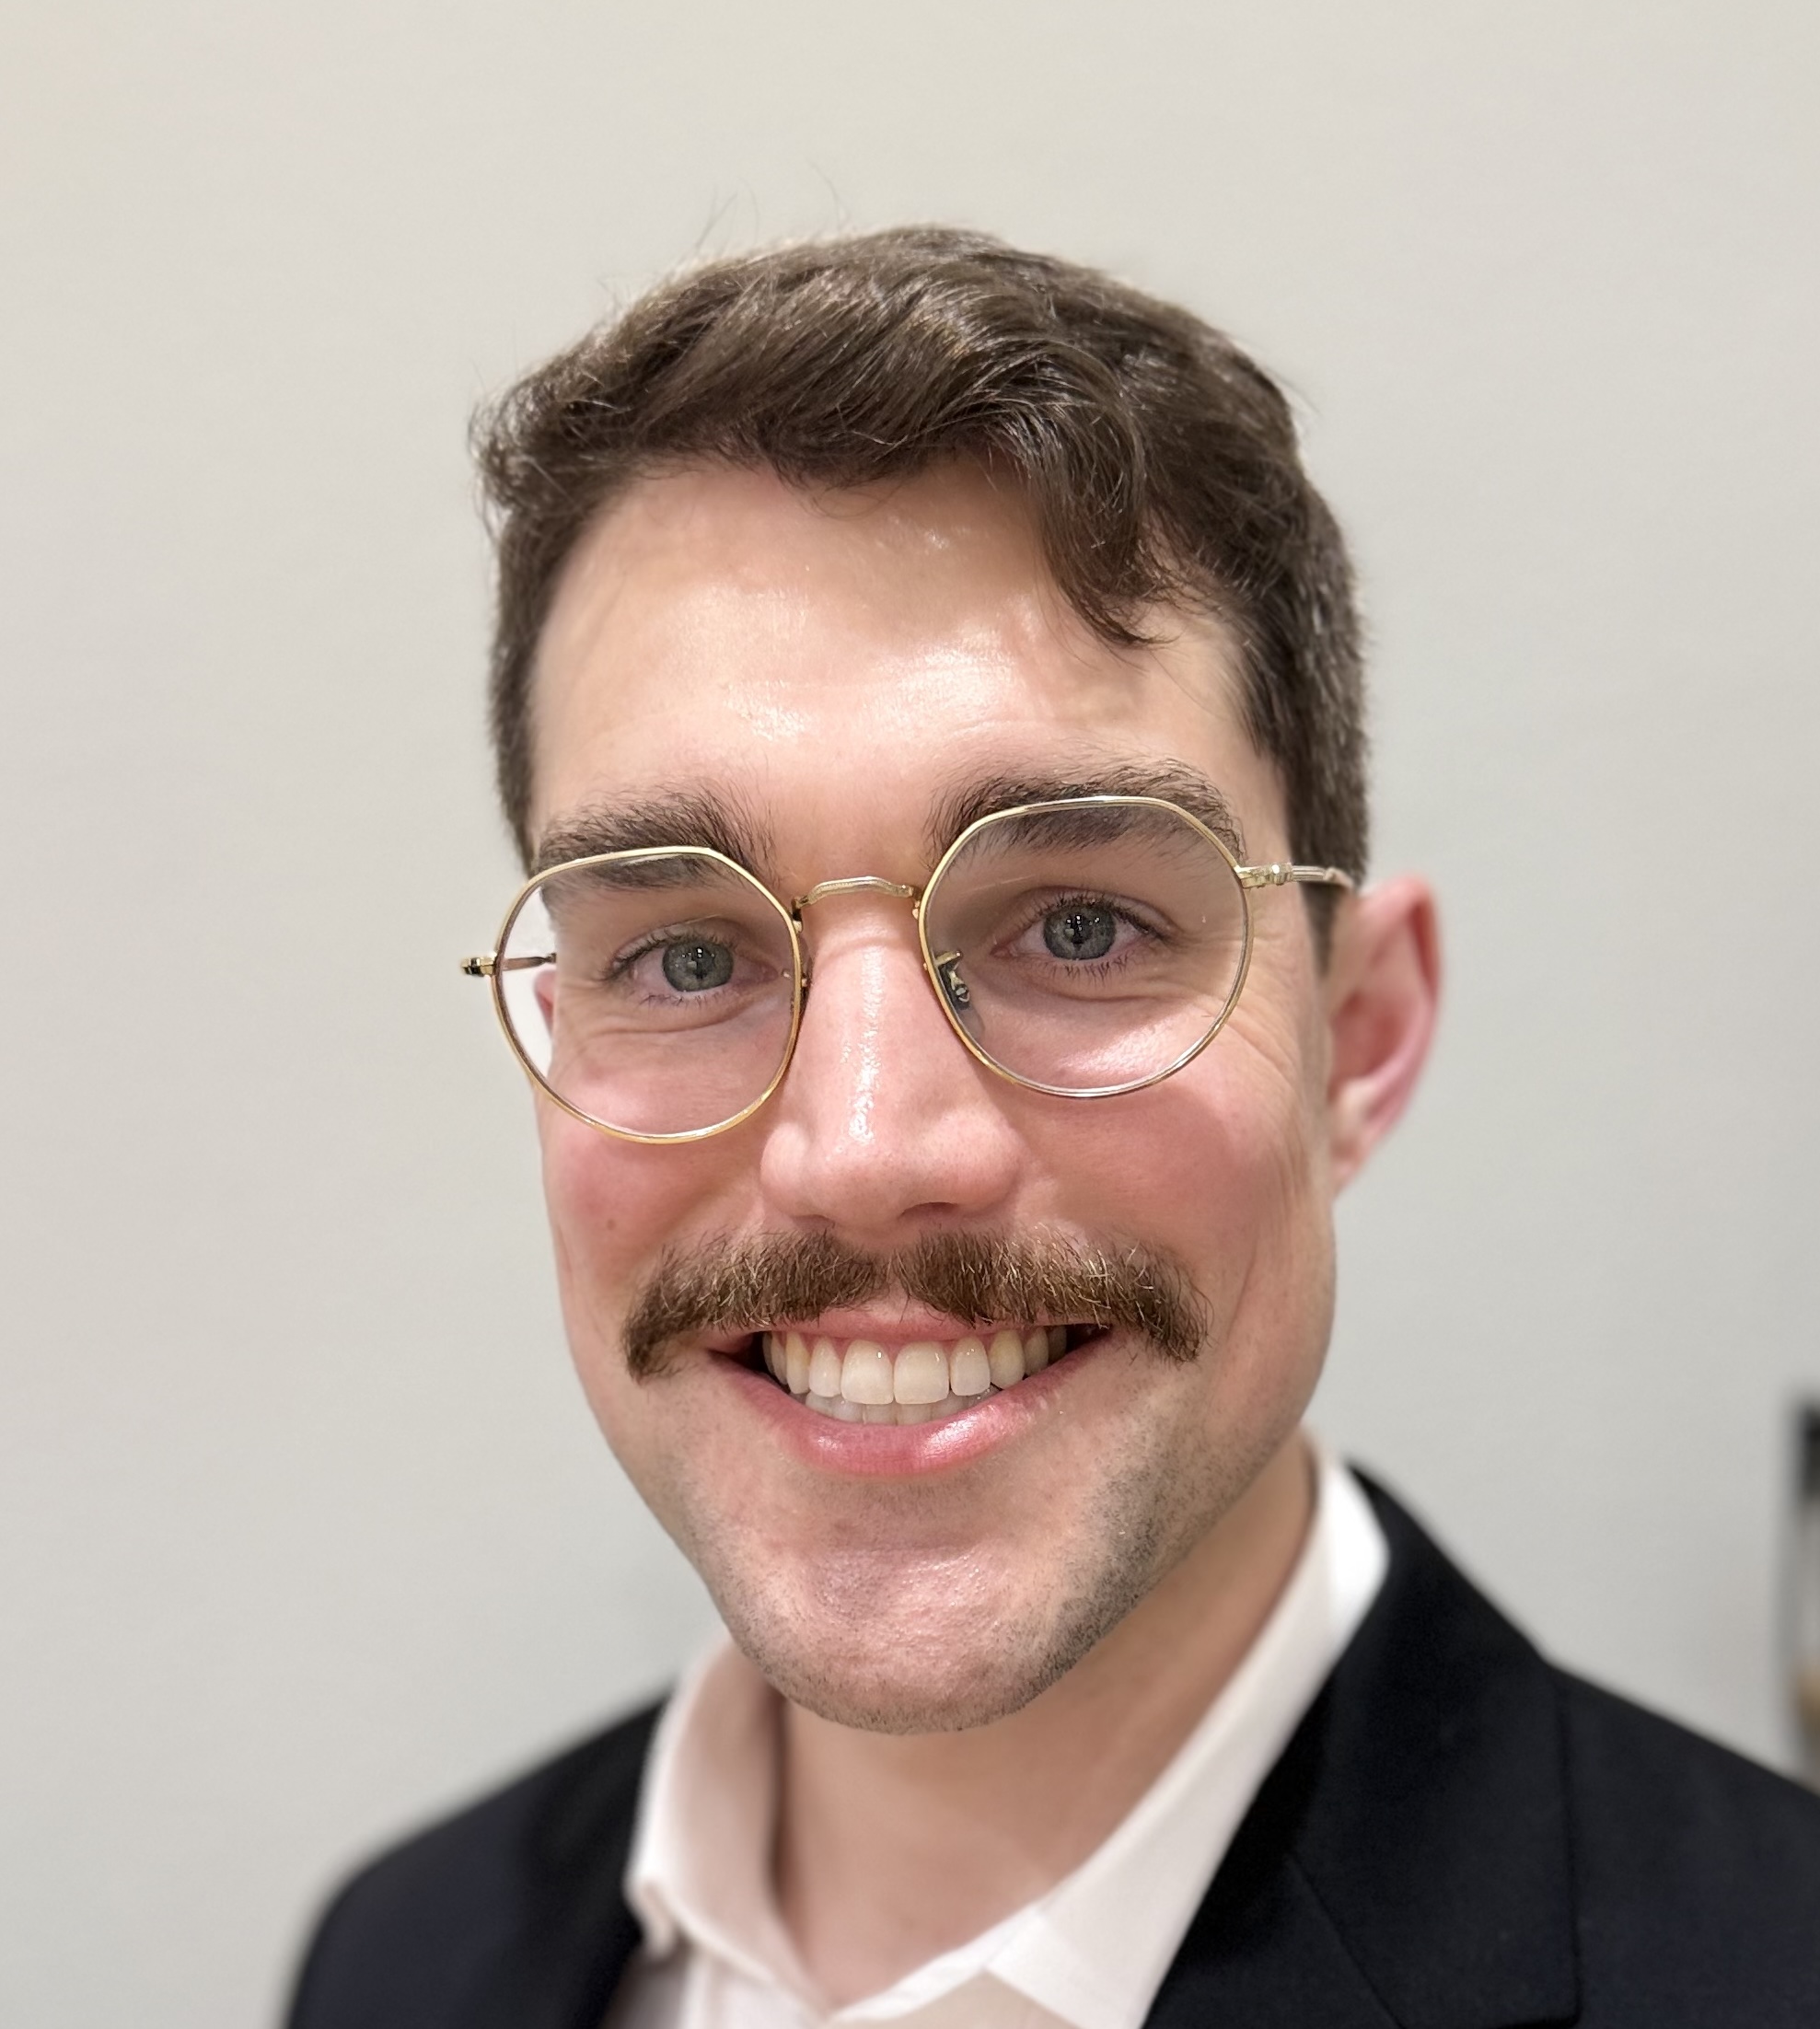
Faculty candidate · 2026–27 academic job market
Postdoctoral researcher · Parasol Lab · UIUC
I am a postdoctoral researcher in the Parasol Lab at the University of Illinois Urbana-Champaign, working with Nancy M. Amato. I earned my Ph.D. in Computer Science at UIUC and my M.S. in Computer Science and B.S. in Computer Engineering at Texas A&M University.
I develop planning systems that help large robot teams work together efficiently. My methods determine which robots need to coordinate and speed up motion planning. Motivated by my industry and startup experience in automated manufacturing, I am extending this work so robot teams can learn from experience and adapt as people direct and participate in their work.
I currently lead research teams involving 12+ graduate students. Through my postdoc and graduate studies, I have mentored 20+ graduate students, including five through degree completion. This work has contributed to 11 student-led publications. I lead the development of three open-source planning libraries and have served as a primary author on NSF and industry research proposals.